Ultra Wideband Positioning is a modern method for locating people, tools, vehicles, and devices with remarkable precision. Unlike traditional Bluetooth proximity estimates, it measures the travel time of radio signals. A small UWB tag sends a short pulse to fixed anchors around a room. The system calculates how long each pulse takes to arrive. Tiny timing differences reveal distance. Several distance measurements then help determine the tag’s position through trilateration.
The process sounds simple. It is not always simple in practice. Walls, metal shelves, moving people, and reflected signals can disturb measurements. Careful anchor placement matters. So does clock synchronization and antenna calibration. In a warehouse, for example, anchors mounted near ceiling corners can guide workers toward a specific pallet location. In hospitals, UWB tags may help locate mobile equipment without relying on vague room-level estimates. IEEE 802.15.4z also supports improved ranging reliability and stronger protection against certain signal attacks.
Accuracy depends on the environment.
A trustworthy deployment needs testing under real conditions, not only laboratory results. Installers should measure blind spots, review battery performance, and confirm that collected location data is handled responsibly. UWB can support safer workflows and faster asset searches, but it cannot solve every tracking problem. Some systems need additional sensors, better maps, or human judgment. It is easy to oversell the technology. A realistic understanding of Ultra Wideband Positioning begins with both its impressive precision and its practical limitations.
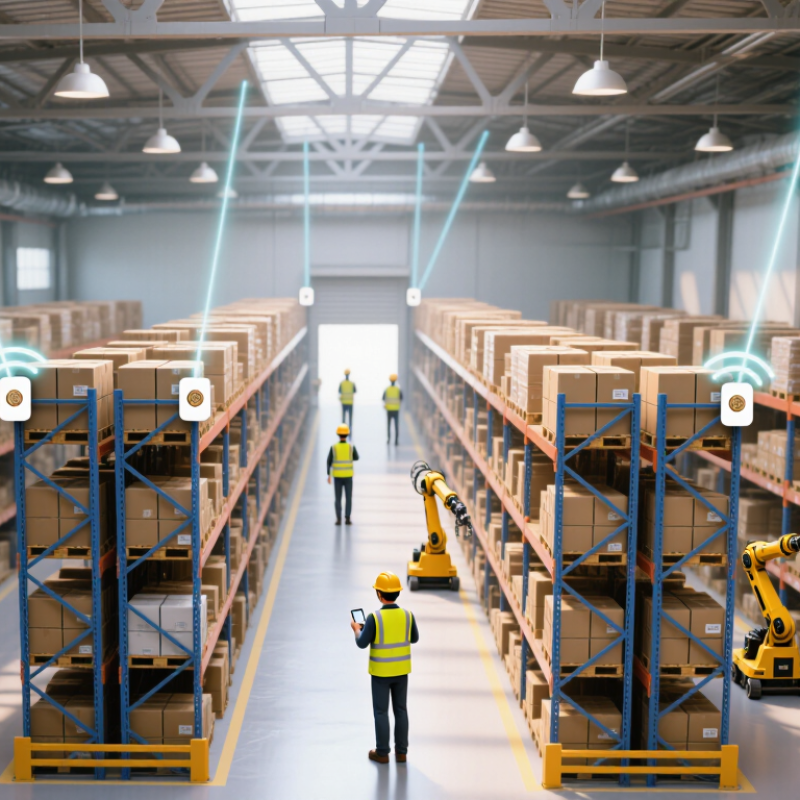
Ultra-Wideband positioning is a radio-based method for measuring location through extremely short pulses. Unlike ordinary wireless systems, it records how long a signal takes to travel between a tag and fixed reference points. The system then converts those timing measurements into distance. A tag may sit inside a warehouse cart, on a tool, or inside a wearable device. Fixed anchors listen from different positions. Their combined readings estimate the tag’s location, often within tens of centimeters in controlled spaces.
The technology operates across a wide frequency range, commonly around 3.1 to 10.6 GHz under United States regulations. Its short pulses can separate reflections more clearly than many narrowband signals. That improves positioning near walls, machinery, and moving people. A 2023 MarketsandMarkets report estimated the ultra-wideband market at about USD 1.6 billion, with continued growth expected through 2028. Berg Insight also identified real-time location systems as a major commercial application, especially in industrial environments. These figures show strong momentum, but market growth does not guarantee perfect accuracy. Metal shelving, blocked paths, and poor anchor placement still create errors. It is not magic. A practical installation needs careful calibration, reliable clock synchronization, and regular testing. Even then, a location estimate remains an estimate, not an unquestionable fact.
What Is Ultra Wideband Positioning and How Does It Work?
How Ultra-Wideband Signals Enable Precise Ranging
Ultra-wideband positioning measures distance through extremely short radio pulses. A tag sends a pulse, and an anchor records its arrival time. The system then estimates the time of flight between both devices. Multiplying that delay by the speed of light produces a distance estimate. Timing matters. A one-nanosecond error represents roughly 30 centimeters of range.
Modern systems use two-way ranging to reduce clock differences. Devices exchange carefully timed messages and calculate the round-trip delay. IEEE 802.15.4z adds stronger ranging methods and improved resistance to manipulated measurements. FiRa Consortium technical materials commonly describe accuracy near 10 centimeters under favorable conditions. However, that figure is not a promise. Metal shelves, wet materials, crowded rooms, and reflected signals can reduce reliability. Walls interfere. Real installations need testing.
Tips: Keep anchors away from large metal surfaces. Survey each room before deployment. Use several anchors for better geometry. MarketsandMarkets projects the UWB market to grow from about USD 1.6 billion in 2023 to USD 3.3 billion by 2028. That growth reflects wider adoption, but market size does not guarantee positioning quality. Measure accuracy at different heights, walking speeds, and times of day. A small calibration error can become a visible map drift.
| Data Dimension | Measured or Defined Value | Unit | Technical Significance |
|---|---|---|---|
| Common UWB Frequency Range | 3.1–10.6 | GHz | This is the widely cited UWB frequency range defined for unlicensed low-power operation in the United States. Permitted bands differ by region and application. |
| Minimum UWB Bandwidth | At least 500 | MHz | A very wide occupied bandwidth allows the receiver to distinguish signal-arrival times more precisely than a narrowband waveform. |
| Alternative Fractional-Bandwidth Criterion | At least 20% | Fractional bandwidth | Fractional bandwidth is calculated as 2 × (upper frequency − lower frequency) ÷ (upper frequency + lower frequency). |
| Speed of Electromagnetic Propagation | 299,792,458 | m/s | Ranging systems use the propagation speed of radio waves to convert measured signal time into distance. |
| Distance Represented by 1 Nanosecond | Approximately 0.30 | m | A one-way timing error of 1 nanosecond corresponds to about 30 centimeters of distance error in free space. |
| Distance Represented by 100 Picoseconds | Approximately 0.03 | m | A 100-picosecond one-way timing interval corresponds to approximately 3 centimeters, illustrating why precise timestamping is essential. |
| Basic Time-of-Flight Formula | Distance = Propagation Speed × Time of Flight | Formula | For one-way ranging, distance is calculated from the elapsed time between transmission and reception. Two-way ranging measures a round-trip interval and applies the appropriate factor. |
| Typical Indoor Positioning Accuracy | About 10–30 | cm | This range is achievable in favorable indoor conditions with suitable antenna placement, calibration, line of sight, and adequate anchor geometry. Actual performance varies. |
| Primary Ranging Method | Time of Flight or Two-Way Ranging | Method | A device estimates distance by measuring how long a radio signal takes to travel between a mobile tag and one or more fixed reference points. |
| Synchronization Requirement for Two-Way Ranging | Reduced compared with one-way ranging | System characteristic | The exchange of timed messages can compensate for much of the clock offset between devices, although clock drift and processing delays still require calibration. |
| Minimum Reference Points for 2D Trilateration | At least 3 | Reference points | Three known distances can theoretically locate a point in two dimensions. Additional reference points improve robustness and help resolve measurement errors. |
| Minimum Reference Points for 3D Trilateration | At least 4 | Reference points | Four or more geometrically suitable reference points are generally required to estimate a three-dimensional position from measured ranges. |
| Common Positioning Techniques | ToF, TDoA, AoA, and Trilateration | Techniques | Time of Flight measures signal travel time, Time Difference of Arrival compares arrival times, Angle of Arrival estimates direction, and trilateration combines multiple distances. |
| Impact of Non-Line-of-Sight Conditions | Positive Range Bias | Typical error behavior | Walls, people, furniture, and other obstacles can delay the first detectable signal path, causing the calculated distance to appear longer than the true distance. |
| Key Accuracy Factors | Clock Precision, Antenna Delay, Multipath, Geometry, and Calibration | Factors | Wide bandwidth alone does not guarantee centimeter-level positioning; system design and environmental conditions strongly influence the final result. |
An ultra-wideband positioning system measures distance through short radio pulses. Its core includes fixed anchors, mobile tags, antennas, and processing software. Anchors sit on walls or ceilings. A tag may travel on a tool cart or helmet. Time-of-flight calculations convert signal travel into location. IEEE 802.15.4z defines enhanced ranging methods for these exchanges. NIST’s indoor-positioning research also stresses clock accuracy and controlled testing.
The radio is only one component. A local controller synchronizes anchors and filters noisy measurements. Location software then compares several distances through multilateration. A 2024 technical review of indoor positioning systems reports typical UWB accuracy near 10–30 centimeters in clear conditions. Performance drops near metal racks, thick concrete, and moving machinery. Walls interfere. Antenna placement matters.
Calibration connects laboratory performance with daily operations. Installers should record anchor height, cable delays, and reference points. A practical test might move one tag beside a doorway, beneath a shelf, and across a loading area. The system should expose confidence levels, not only coordinates. That detail helps technicians question an apparently precise result. In my experience, maintenance is underestimated; a shifted anchor can create a clean-looking but incorrect map. Battery status, firmware consistency, and timestamp drift also deserve monitoring. The weak point is often the deployment plan, not the signal.
Ultra Wideband Positioning estimates location by measuring how long radio signals take to travel. The system uses fixed anchors and a mobile tag. Each anchor records a signal’s arrival time. Radio waves move extremely fast. A timing error of one nanosecond can create roughly 30 centimeters of distance error. The tag’s position comes from several measured distances, not from one signal alone.
The calculation is called multilateration. A processor compares the time differences between anchors, then draws possible distance circles around them. Where those measurements overlap, the tag is likely located. Three anchors can estimate a two-dimensional position, while four or more usually support three-dimensional tracking and better timing correction. Real systems also compensate for clock drift, antenna delays, and signal reflections. Concrete walls, metal shelves, and people can distort the path. The result may jump briefly. It is not magic, and it is not flawless.
Tips: Place anchors at different heights and avoid hiding them behind metal. Keep the geometry wide rather than grouping anchors together. Watch confidence values, not just the displayed coordinates. Test the system with a tape measure in the actual room. A clean laboratory result may weaken near machinery or crowded corridors. Filtering can smooth movement, but excessive filtering creates noticeable lag. Check both accuracy and response time.
UWB positioning estimates the distance between a tag and several fixed anchors by measuring signal time of flight. The measured distances are combined through multilateration to calculate the tag position. In this example, the estimated position is approximately (4.1 m, 5.9 m) on a two-dimensional floor plan.
The comparison shows the measured ranges and the ranges expected from the calculated position. Small differences are normal because of clock uncertainty, reflections, antenna delay, and measurement noise.
Ultra-wideband positioning estimates location by measuring how long radio pulses take to travel between a tag and fixed anchors. Its accuracy can reach centimeters in controlled conditions. Real environments are less cooperative. Walls, metal shelves, glass, and machinery can reflect pulses. These reflections create multipath errors, making a tag appear several centimeters away.
Anchor placement strongly affects the result. Anchors should surround the working area rather than sit along one wall. Their height also matters. Mounting them too low may increase blockage from people, carts, or furniture. Poor geometric layouts can amplify small timing errors. A stable installation needs measured anchor coordinates, secure mounting, and careful calibration.
Signal quality changes with antenna direction and the user’s body. A hand covering the tag can weaken or delay the signal. Moving objects may briefly distort measurements. Clock synchronization, firmware settings, battery condition, and local radio activity also deserve attention. Field tests should include walking, turning, crouching, and stopping near obstacles. A clean laboratory result may not represent a busy warehouse. I have found that repeated tests often reveal small errors that a single demonstration hides. Even then, perfect accuracy is an unrealistic target.
Get in Touch
570 Alden Road Unit #10, Markham Ontario Canada, L3R 8N5
Quick Links
Featured Products
Industries